It is with great pleasure that we invite you to the 2026 International Conference on Embodied Human-Robot Intelligence (EHRI 2026) which is scheduled to be held in Chengdu, China, on December 5-7, 2026. EHRI 2026 is organized by the University of Electronic Science and Technology of China, and technically co-sponsored by IEEE Chengdu Section.
Embodied human-robot intelligence is rapidly transforming the way intelligent systems perceive, learn, interact, and collaborate with humans in real-world environments. Driven by breakthroughs in artificial intelligence, robotics, sensing technologies, and human-robot interaction, the field is enabling the development of more adaptive, autonomous, and human-centered robotic systems.
EHRI 2026 welcomes contributions from academia and industry across a broad range of related disciplines. The conference will foster interdisciplinary collaboration and discussion on emerging challenges, innovative technologies, and future directions in embodied intelligence and human-robot systems.
|
Third Round |
Please log in to the online registration system to fill in your information and complete the payment.
会议报名及相关会议信息请使用微信扫描以下二维码。
· USD Payment |

The topics of relevance for the conference papers include but not limited to the following:
 Embodied Perception and Sensing Learning for Embodied Intelligence Human-Robot Interaction and Collaboration Cognitive Architectures and Decision Making Embodied Control and Motion Generation Applications, Safety, and Trust Other Related Topics
Please submit your paper to: Online Submission System 
(Please try to use Google Chrome if you encounter any issues during your submission or registration process. You may also contact us at 028-85586839 for any assistance.)
If you have any questions during the submission process, please send an email to: email@icehri.org.
Only original papers will be considered. The manuscripts must not be previously published or accepted for publication elsewhere. Must not be under review by any other conference or publication during the review cycle.
Authors are encouraged to check the similarity index of their paper before submission. Papers suspected of plagiarism, self-plagiarism, repeated publication, etc. will be rejected without further consideration.
All the submitted papers must adhere to the conference written paper format. For the detailed format information, please download here:
Full Paper Template:  /
 Abstract Template:

Sessions | 特别专题
Session Ⅰ Embodied Human-Robot Interaction and Collaborative Manipulation
Chair: Dr. Xiuze Xia, Ocean University of China, China
Co-chairs: Reader Yanan Li, University of Sussex, UK
Assoc. Researcher Houcheng Li, Institute of Automation,Chinese Academy of Sciences, China
Senior Lecturer Ildar Farkhatdinov, King's College London, UK
Session Ⅱ: Bioinspired Robot
Chair: Prof. Yichuan Wu, University of Electronic Science and Technology of China, China
Session Ⅲ : Safe Learning and Control for Embodied Human–Robot Interaction
Chair: Assoc. Professor. Yunda Yan, University College London, UK
Co-chairs: Lecturer Zezhi Tang, University College London, UK
Lecturer Chengyuan Liu, Loughborough University, UK
Registered and presented full papers will be included in the EHRI 2026 digital conference proceedings and submitted to major citation databases (including, but not limited to Ei Compendex and Scopus) for review and indexing.
Note: All accepted papers must be presented at the conference. No-show papers will be excluded from the conference proceedings.
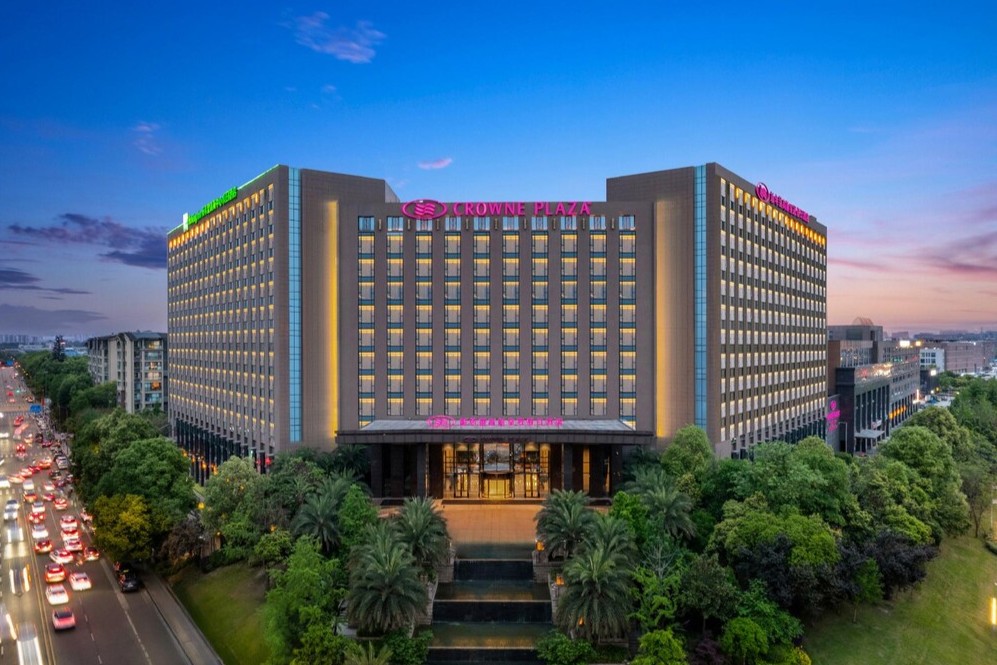
Crowne Plaza Chengdu West | 成都新希望高新皇冠假日酒店
Address: No.1 Xixin Avenue, High-Technology West Zone, Chengdu, Sichuan, China
地址:中国四川省成都市高新西区西芯大道1号